Screwdriving
This section describes how to control the screwdriving system using the I/O interface of the SpinBridge.
Definition of TCP positions
During screwdriving, the robot must move to different positions to drive the screw. The axis of the screwdriver must be alligned with the hole in the workpiece. The tool center point is the tip of the bit, and the following positions are defined along the screwdriving axis with the bit in the screw:
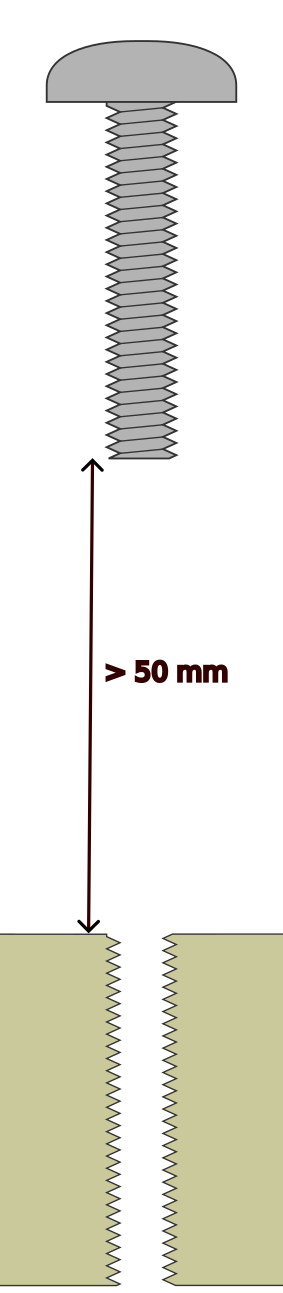
Safe: For the safety system to work correctly in a collaborative application, the robot must approach the screw from a position where the tip of the screw is at least 50 mm directly above the surface of the workpiece. The safety shield must cover the screw.
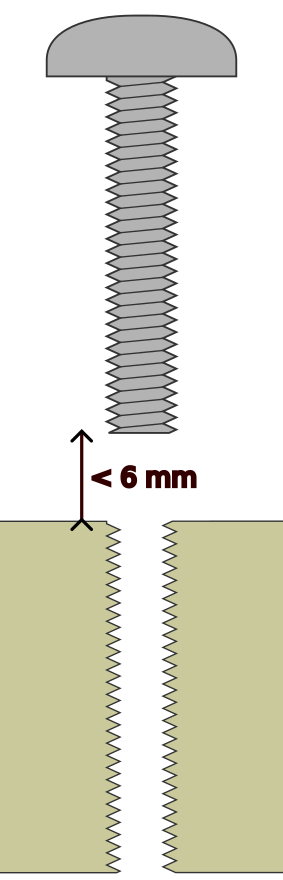
Start: The robot must be positioned so the screw tip is no more than 6 mm above the surface of the workpiece. This distance should ideally match the Start depth parameter in the screw program (note that the value of the insertion depth is negative at this position). In a collaborative application, the safety shield must begin to retract at this position.
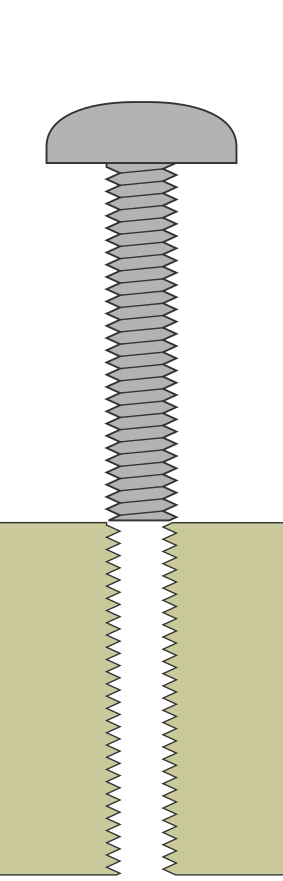
Contact: The screw tip is in contact with the workpiece. In a tightening program, the screw program is started here and enters the Rundown step.
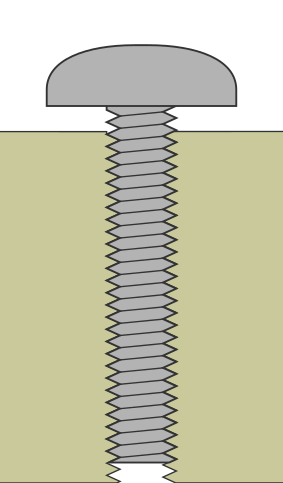
Tighten: Enter Tighten Step. The screwdriver slows down about 3 mm from the seated position, and the screw is driven to the desired torque.
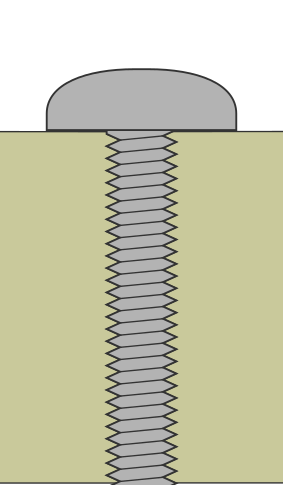
Seated: The screw is seated in the workpiece. The screwdriver has stopped driving the screw.
Tightening - follow screw using force
Follow this guide to create a collaborative tightening sequence, where the robot follows the screw down in force mode with an appropriate force and maximum speed setting. Start by creating a screwdriving program.
Go to Dashboard > Programs > Add new program to create a screwdriving program with parameters that suites the screw and application.
Use the Quick Tightening strategy and select Robot follows screw using Speed. This will create a two-step screwdriving program with the steps Rundown and Tighten. In each step the robot speed is calculated based on the screwdriver motor speed and the pitch of the screw.
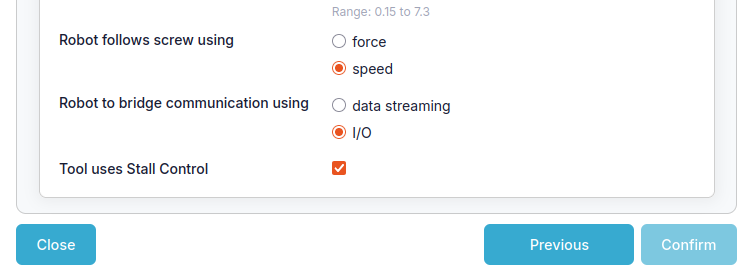
Wizard step 4 - Overview: These settings should be automatically configured based on the connected screwdriver and robot. Although the robot must follow the screw using force, you should select the Robot follows screw using Speed option in the screwdriving program. The Robot follows screw using Force option is not supported in I/O control mode, and selecting it will prevent the robot speed from being calculated.
Open the program and check the parameters. In the first step, Rundown, the Start safety shield must be checked.
Now the program can be mapped to an action in the I/O control. Go to Dashboard > I/O Control > Actions and map the action Start Screw Program, with the name of the program you just created as the action parameter.
Map the action Safety Shield Move with the parameter -20.0. This makes the safety shield move upwards with a speed of 20 mm/s.
Map the action Safety Shield Stop.
Map the action Safety Shield Cover Bit.
Create the following robot sequence to drive in a screw. It is assumed that, the system is enabled and ready, a screw is loaded and that the safety shield covers the screw:
Move the robot to the Safe position.
Move linearly to the Start position. Speed 100 mm/s.
Start the Safety Shield Move action.
Move the robot linearly to the Contact position. Speed 20 mm/s. On many robots this can be done with a command that makes the robot move until tool contact is detected.
Start the Safety Shield Stop action.
Start the Start Screw Program action.
Put the robot in force mode with a force of 20N in the direction of the screwdriving axis.
Wait for either DO4, DO5 or DO6 to go high. This indicates that the screw is done.
Move the robot up to the Safe position.
Start the Safety Shield Cover Bit action.
Tightening - follow screw using speed
Follow this guide to create a collaborative screwdriving sequence where the robot follows the screw down by setting speeds that matches the screwdriver motor speed and the pitch of the screw. The robot motion must be alligned with the parameters in the screw program for the screw to be driven in correctly and safely. Start by creating a screwdriving program.
Go to Dashboard > Programs > Add new program to create a screwdriving program with parameters that suites the screw and application.
Use the Quick Tightening strategy and select Robot follows screw using Speed. This will create a two-step screwdriving program with the steps Rundown and Tighten. In each step the robot speed is calculated based on the screwdriver motor speed and the pitch of the screw.
Wizard step 4 - Overview: These settings should be automatically configured based on the connected screwdriver and robot. Although the robot must follow the screw using force, you should select the Robot follows screw using Speed option in the screwdriving program. The Robot follows screw using Force option is not supported in I/O control mode, and selecting it will prevent the robot speed from being calculated.
Open the program and check the parameters. In the first step, Rundown, the Start safety shield must be checked.
Now the program can be mapped to an action in the I/O control. Go to Dashboard > I/O Control > Actions and map the action Start Screw Program, with the name of the program you just created as the action parameter.
Map the action Safety Shield Move with the parameter -20.0. This makes the safety shield move upwards with a speed of 20 mm/s.
Map the action Safety Shield Stop.
Map the action Safety Shield Cover Bit.
Create the following robot sequence to drive in a screw. It is assumed that, the system is enabled and ready, a screw is loaded and that the safety shield covers the screw:
Move the robot to the Safe position.
Move linearly to the Start position. Speed 100 mm/s.
Start the Safety Shield Move action.
Move the robot linearly to the Contact position. Speed 20 mm/s. On many robots this can be done with a command that makes the robot move until tool contact is detected.
Start the Safety Shield Stop action.
Start the Start Screw Program action.
Move the robot linearly with blend to the Tighten position. The speed of the robot must match the Driving speed parameter in the screw program’s Rundown step.
Move the robot linearly with blend to the Seated position. The speed of the robot must match the Driving speed parameter in the screw program’s Tighten step.
Wait for either DO4, DO5 or DO6 to go high. This indicates that the screw is done.
Move the robot up to the Safe position.
Start the Safety Shield Cover Bit action.
Loosening - follow screw using force
Follow this guide to create a collaborative loosening sequence, where the robot follows the screw in force mode with an appropriate force and maximum speed setting. Start by creating a screwdriving program.
Go to Dashboard > Programs > Add new program to create a screwdriving program with parameters that suites the screw and application.
Use the Loosening strategy and select Robot follows screw using Speed. This will create a two-step screwdriving program with the steps Locate screw and Runup. In each step the robot speed is calculated based on the screwdriver motor speed and the pitch of the screw.
Wizard step 4 - Overview: These settings should be automatically configured based on the connected screwdriver and robot. Although the robot must follow the screw using force, you should select the Robot follows screw using Speed option in the screwdriving program. The Robot follows screw using Force option is not supported in I/O control mode, and selecting it will prevent the robot speed from being calculated.
Open the program and check the parameters. In the first step, Locate screw, the Start safety shield must be checked.
Now the program can be mapped to an action in the I/O control. Go to Dashboard > I/O Control > Actions and map the action Start Screw Program, with the name of the program you just created as the action parameter.
Map the action Safety Shield Move with the parameter -20.0. This makes the safety shield move upwards with a speed of 20 mm/s.
Map the action Safety Shield Stop.
Map the action Safety Shield Cover Screw with the parameter set to the length of the screw in mm.
Create the following robot sequence to drive out a screw. It is assumed that the system is enabled and ready and that the safety shield covers the bit. In the following you can refer to the definitions of the TCP position above, but keep in mind that there is no screw on the tool.
Move the robot to the Safe position, where the tip of the bit is at least 50 mm above the surface of the workpiece.
Move linearly to the Start position, where the bit is 6 mm above the screw. Speed 100 mm/s.
Start the Safety Shield Move action.
Move the robot linearly to the Seated position. Speed 20 mm/s. On many robots this can be done with a command that makes the robot move until tool contact is detected.
Start the Safety Shield Stop action.
Start the Start Screw Program action.
Put the robot in force mode with a force of 10N in the direction of the screwdriving axis.
Wait for either DO4, DO5 or DO6 to go high. This indicates that the screw is done.
Move the robot up to the Safe position.
Start the action Safety Shield Cover Screw.
Move the robot away.
Loading screws
Follow theese steps to create a collaborate loading sequence, where the robot loads a screw into the screwdriver from a screw feeder. Start by mapping actions.
Go to Dashboard > I/O Control > Actions and map the action Safety Shield Cover Screw with the parameter set to the length of the screw in mm.
Map the action Safety Shield Move with the parameter -10.0. This makes the safety shield move upwards with a speed of 10 mm/s.
Map the action Safety Shield Stop.
Map the action Safety Shield Cover Bit.
Map the action Start Motor with the parameter set to 30. This will start the screwdriver motor with a speed of 30 rpm.
Map the action Stop Motor.
Create the following robot sequence to load a screw. It is assumed that the system is enabled and ready and that the safety shield covers the bit.
Move the robot to the Safe position, where the bit is at least 50 mm above the screw feeder.
Move linearly to the Start position, where the bit is 6 mm above the screw. Speed 100 mm/s.
Start the Start Motor action.
Start the Safety Shield Move action.
Move the robot linearly to the feeder position. Speed 10 mm/s.
Start the Safety Shield Stop action.
Start the Stop Motor action.
Move the robot up to the Safe position.
Start the Safety Shield Cover Screw action.
Non-collaborative applications
In non-collaborative applications, the robot can be programmed to drive in screws without covering the screw and bit with the safety shield. The screwdriving sequences can be used as described above, but the safety shield actions can be omitted, and in the screw programs the Start safety shield should not be checked in any steps. Furthermore, the robot can be programmed to move the screwdriver directly to the Start position.