Connecting Safety to Robot or PLC
The safety output from the Spin Bridge must be connected to a safety input of the robot or PLC (e.g., emergency stop or safeguard stop circuit).
The Spin Bridge provides safety output as OSSD signals. These signals are designed to initiate a safe stop of the robot when the tool safety system is triggered. The OSSD signals are dual-channel safety outputs designed for Category 3 / Performance Level d (PL d) safety systems.
Safety Signal Overview
The safety system operates as follows:
The tool detects unexpected contact (safety sensor)
The Spin Bridge outputs a safety signal (OSSD)
The robot or PLC must initiate a safe stop
Note
The connected system must be able to receive and react to OSSD safety signals.
The safety system is illustrated in the figure below.
It shows how the safety signal is transmitted from the tool, through the Spin Bridge, to the robot controller, and how the power supply is provided from the robot to the safety system.
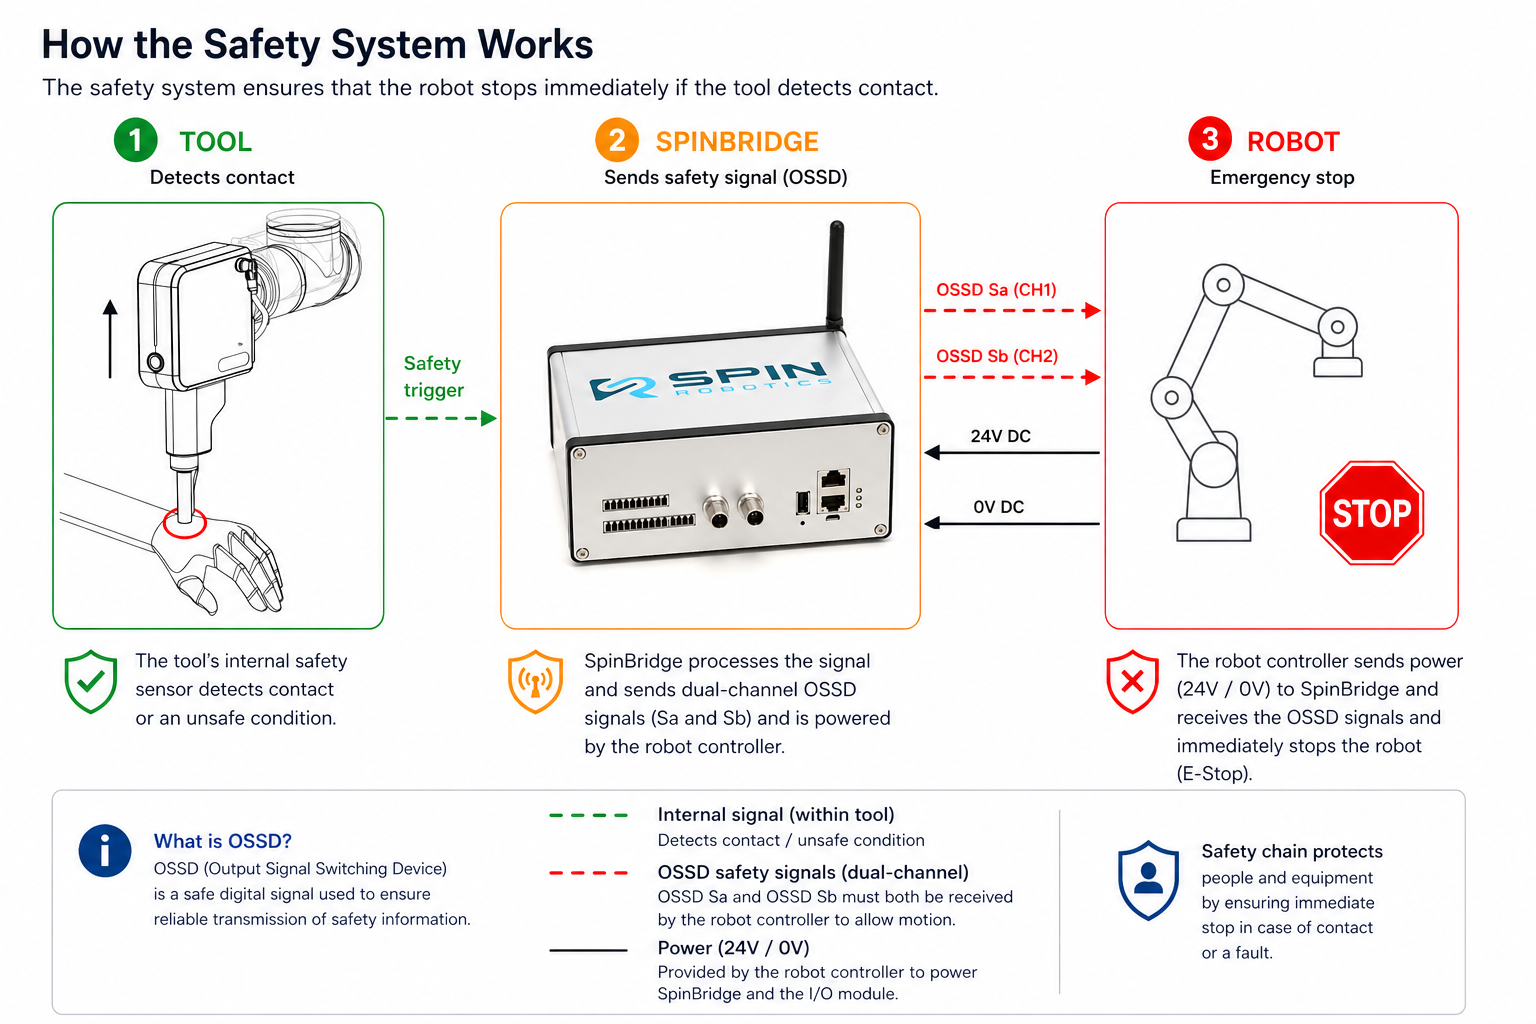
Safety signal flow from tool to robot controller.
The tool detects contact and triggers the safety system. The Spin Bridge transmits dual-channel OSSD signals (S_a and S_b) to the connected controller, which must initiate a safe stop.
The robot controller provides 24 V and 0 V supply to the Spin Bridge.
Both OSSD channels (S_a and S_b) must be active (high) to allow robot operation. The dual-channel design provides redundancy and fault detection: if either channel is interrupted or goes low, the controller must perform a safe stop.
Warning
If the safety cable is not correctly connected, the safety function will not operate. The system must NOT be used in collaborative applications without a functioning safety connection.
Electrical Requirements
The Spin Bridge and the robot or PLC must share the same electrical reference: 24 V and 0 V from the safety cable must be connected, and the safety input circuit must use the same voltage potential. The shared reference is required for both safety signal integrity and I/O communication.
Warning
If 24 V and 0 V are not shared, safety signals may not be detected, the system may behave unpredictably, and the safety function may fail. Connect 24 V and 0 V from the safety cable to the robot or PLC.
Connection Principles
Two typical connection methods are used:
1. Direct OSSD connection (recommended)
Connect OSSD outputs from Spin Bridge directly to robot/PLC safety inputs
Requires support for OSSD signals
2. Safety relay (if OSSD not supported)
Use a safety relay to convert OSSD signals
Relay output connects to robot/PLC E-stop circuit
Note
Always verify compatibility with your robot or PLC safety input specifications.
How to wire the safety cable to a Universal Robots or Kassow robot, or to another robot or a PLC, is described in Connect the Safety Signal.
Verification
After connecting the safety system:
Power on the system
Trigger the safety sensor (e.g., push the tool upward)
Confirm that the robot stops immediately
Warning
If the robot does NOT stop, the safety function is not working. Do NOT operate the system; check wiring and safety configuration.
Common Mistakes
Most common safety issues:
Missing shared 24 V/0 V reference
Incorrect wiring of OSSD signals
Robot not configured for safety input
Missing safety relay (non-OSSD systems)