Payload & Center of Mass (COG)
This section defines the center of gravity (COG) and payload for the SD/SDV-Series screwdriver tools.
The values are intended for robot configuration and dynamic load calculations.
Reference Coordinate System
The coordinate system used for calculating the center of mass is shown below.
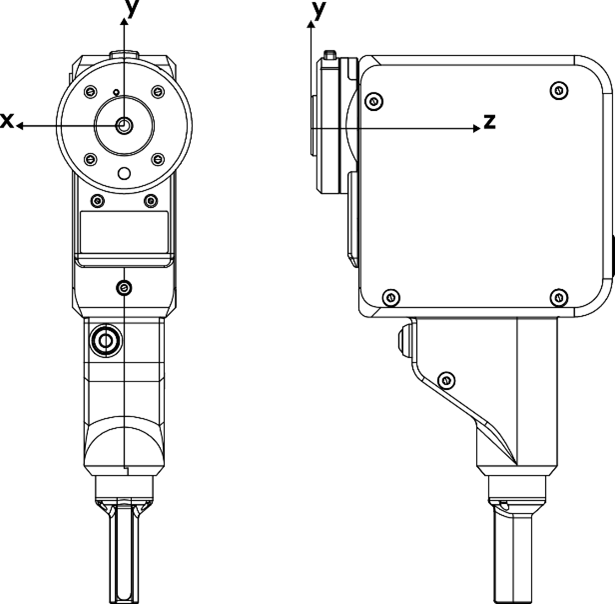
The reference point is located at the tip of a 50 mm screwdriver bit (or teach pointer).
Note
The values represent a typical configuration with the safety shield mounted, a 50 mm bit installed, and no screw attached.
Center of Gravity (COG)
CX (mm) |
CY (mm) |
CZ (mm) |
|
|---|---|---|---|
SD/SDV35 |
-2 |
-54 |
79 |
SD/SDV50 |
-2 |
-54 |
79 |
SD/SDV70 |
-2 |
-54 |
79 |
SD/SDV120 |
-2 |
-52 |
80 |
Payload
Model |
Payload |
|---|---|
SD/SDV35 |
2.6 kg (5.73 lbs) |
SD/SDV50 |
2.6 kg (5.73 lbs) |
SD/SDV70 |
2.6 kg (5.73 lbs) |
SD/SDV120 |
2.7 kg (5.95 lbs) |
Usage in Robot Configuration
The payload and COG values must be configured in the robot controller to ensure correct motion planning and safe operation.
Important Considerations
The actual COG and payload vary with bit length and type, screw size and weight, vacuum tubing and fittings, and any mounted accessories. The integrator must validate the final configuration.
Note
Always verify robot payload limits and dynamic performance when operating at high speeds or accelerations.