Position of Tool Center Point (TCP)
The Tool Center Point (TCP) is defined at the tip of the screwdriver bit.
The TCP is specified relative to the robot tool flange coordinate system.
Reference Definition
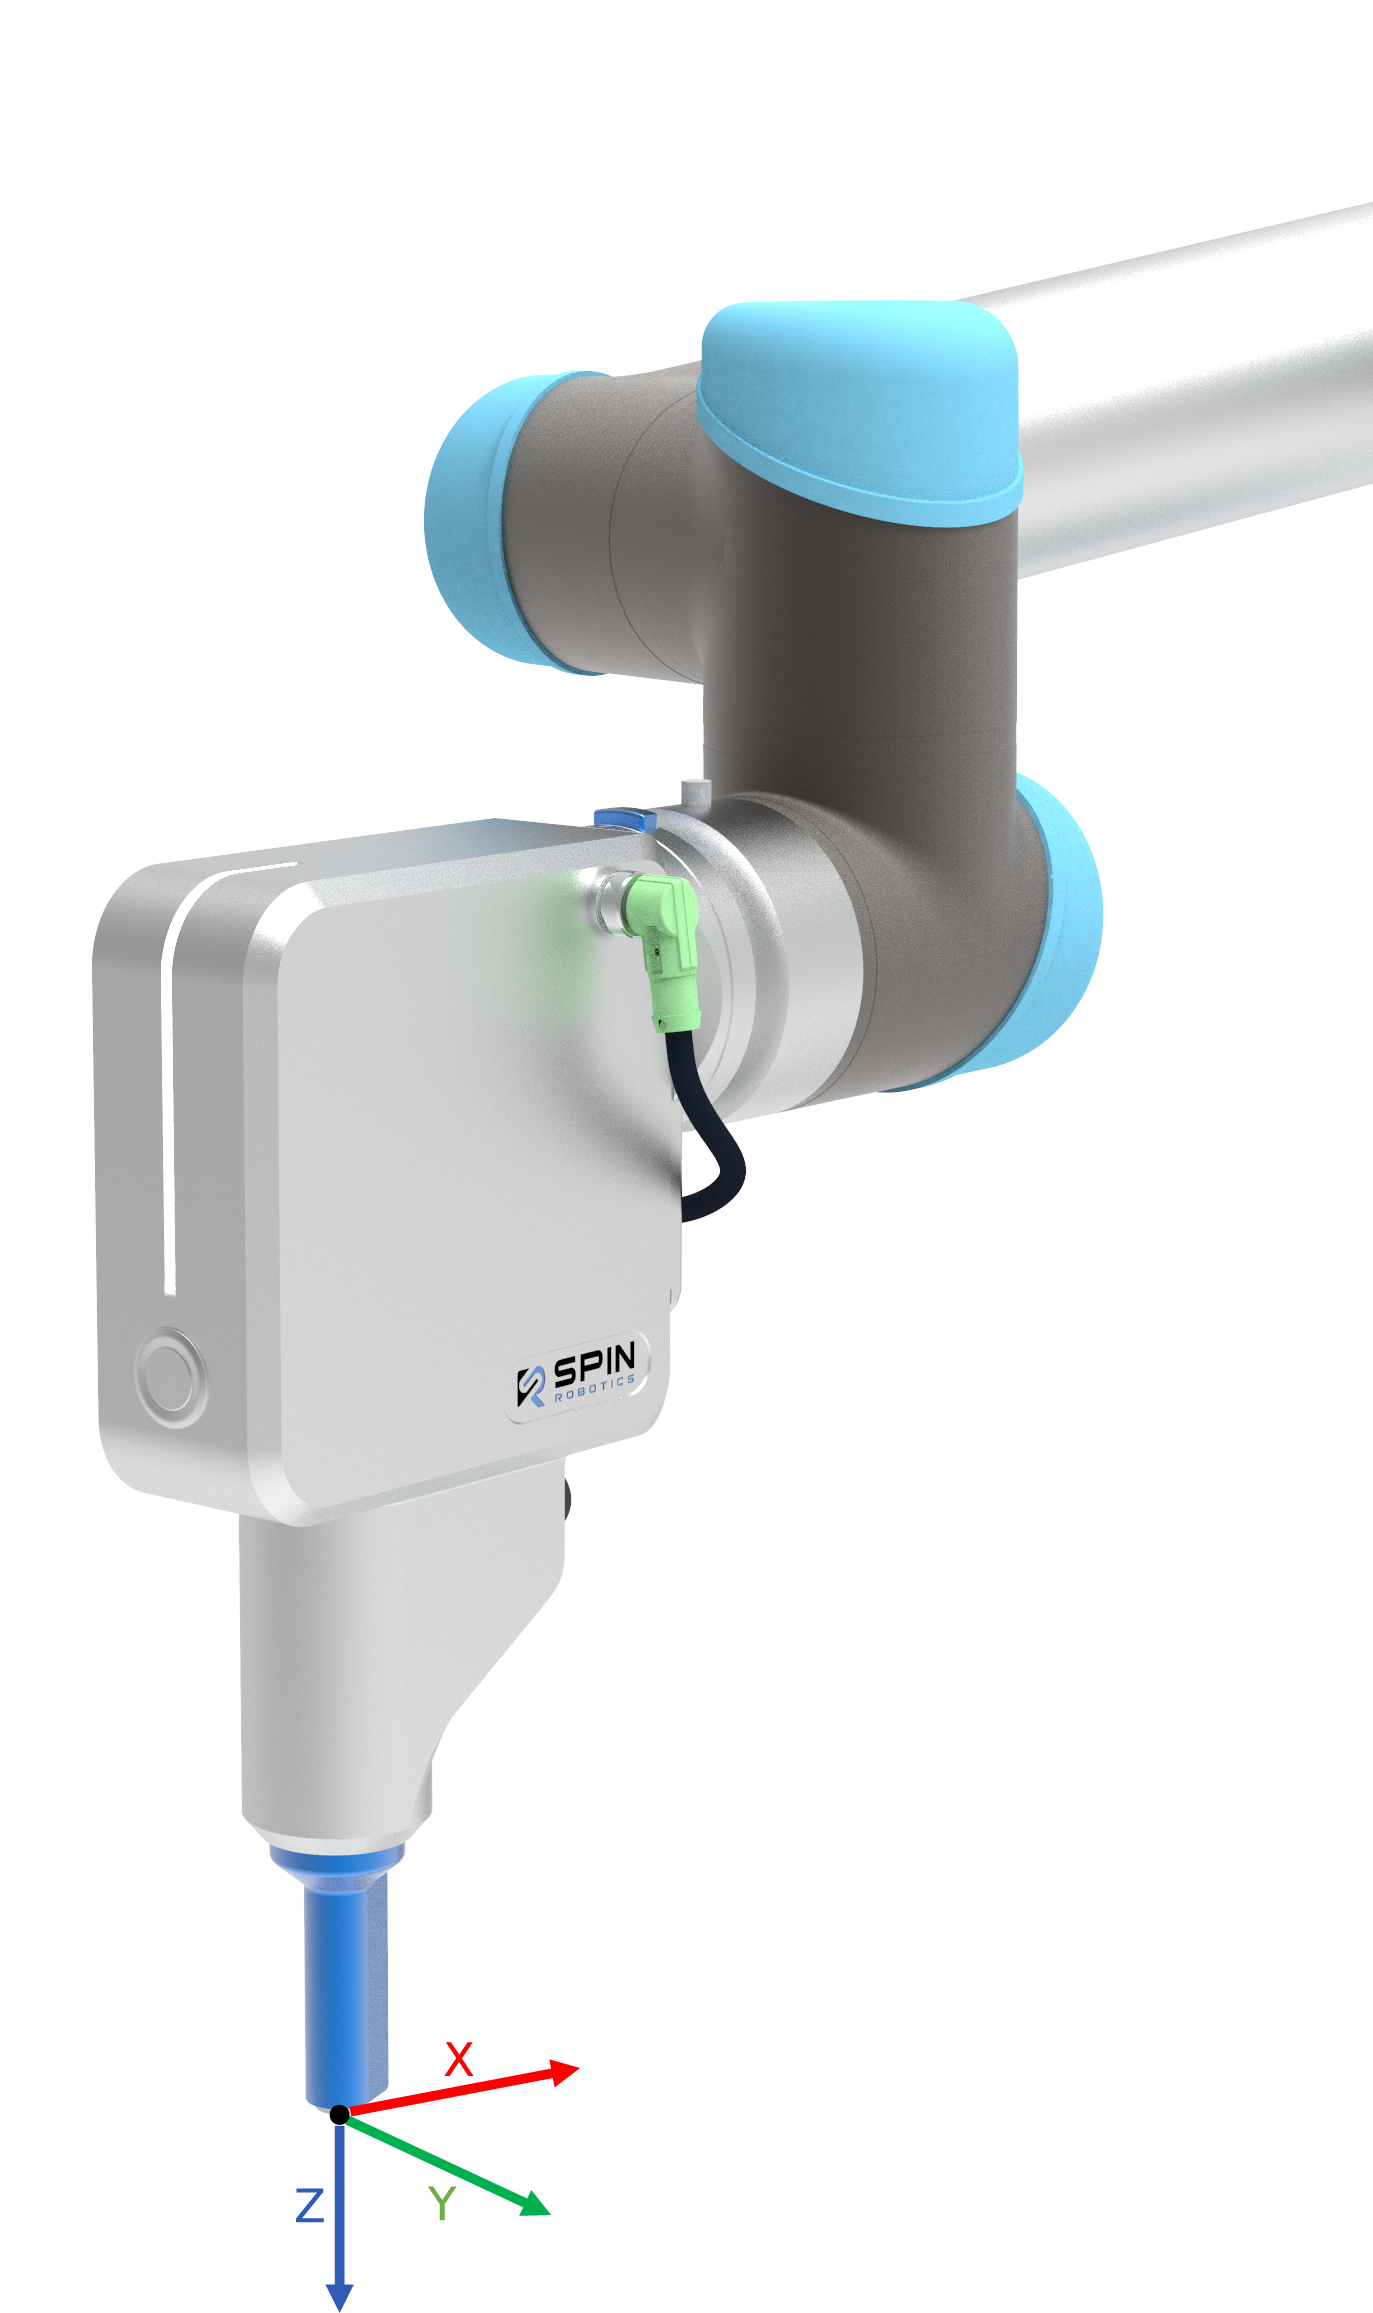
The reference point corresponds to the tip of a 50 mm screwdriver bit (or teach pointer).
TCP Position and Orientation
The TCP is the same for every model. The orientation is given as an axis-angle rotation (RX, RY, RZ).
Component |
Value |
|---|---|
X |
0 mm |
Y |
-264 mm* |
Z |
105 mm |
RX |
1.5708 rad |
RY |
0 rad |
RZ |
0 rad |
* Older SD35 tools have a Y of -248.6 mm.
Note
For robots using different coordinate conventions (e.g., Euler angles), conversion may be required.
Note
The TCP values are based on a standard configuration with a 50 mm screwdriver bit. The TCP must be adjusted if the bit length changes, or the tool is mounted differently on the robot, e.g., using a 3rd party tool changer.
Usage in Robot Configuration
The TCP must be configured in the robot controller to ensure:
Accurate positioning
Correct screw insertion depth
Proper motion planning