Tool Orientation and Safety System
The SD/SDV-Series tool includes a spring-loaded safety mechanism that monitors the axial force applied during screwdriving.
This safety system limits both the usable tool orientations and the maximum applicable axial force.
Tool Orientation
The tool is designed for:
Vertical operation (recommended)
Horizontal operation
Operation in upward direction (screwing upward) is not supported with the standard safety configuration.
Maximum Axial Force
The maximum axial force that can be applied by the tool depends on the orientation.
Orientation |
Maximum axial force [N] |
|---|---|
Vertical
|
48 ± 3 |
Horizontal
|
26 ± 3 |
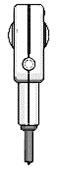
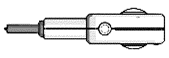
These values define the maximum contact force during operation.
Safety Function
The axial force is monitored by the integrated safety sensor.
If the applied force exceeds the specified limits:
The safety system is triggered
The robot will perform a safety stop
Upward Operation (Important)
Note
Upward screwdriving is not supported with the standard tool configuration. Due to the spring-loaded safety mechanism, the safety sensor will be activated before sufficient axial force can be applied.
If upward operation is required:
The internal springs must be replaced with stiffer springs
The safety system will no longer function as intended
Warning
Disabling or modifying the safety system removes the built-in safety functionality of the tool. The integrator must implement alternative safety measures in compliance with applicable standards.
Relation to Risk Assessment (ISO/TS 15066)
The SD/SDV-Series tool is designed to support integration in collaborative robot applications.
The axial force generated by the tool is limited by the integrated spring-loaded safety mechanism.
This characteristic can be used as part of the system risk assessment.
Note
The tool does not ensure compliance with ISO/TS 15066 on its own. Compliance must be verified at system level by the integrator.
Integration Guidance
During risk assessment, the following should be considered:
Contact between tool and human body
Contact between robot and surroundings
Required axial force for screwdriving
The integrator must verify that:
Applied forces are within acceptable limits
Protective measures are implemented where required
Application Notes
The required axial force depends on screw type and application. If it is insufficient the bit may slip and the screw will not be driven correctly. For best performance use vertical orientation where possible, use an appropriate bit type in good condition, and replace worn bits regularly.